Coverage & mapping
Planning where aerial robots should move and at what altitude to gather useful information efficiently.
Robotics · Autonomy · Multi-agent systems
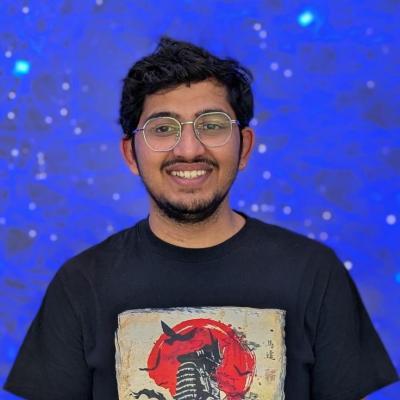
I’m Swaraj Nistane, a Computer Science PhD student at the University of Georgia’s Heterogeneous Robotics Lab. My research develops distributed planning and control methods for multi-UAV coverage, tracking, and intelligent information gathering.
Research focus
Planning where aerial robots should move and at what altitude to gather useful information efficiently.
Designing local decision rules that let robot teams coordinate without depending on a single central controller.
Developing guidance and control methods for persistent target tracking under sensing, motion, and safety constraints.
Featured work
Multi-UAV Sensor Coverage with Altitude Optimization for Target Tracking
Presented at the IEEE ICRA 2025 Workshop on 25 Years of Aerial Robotics. The work studies the tradeoff between sensing footprint and measurement quality when UAV altitude becomes a planning variable.
Publication detailsBackground
Before beginning my PhD in Computer Science, I earned a BS–MS in Physics from the Indian Institute of Science Education and Research Bhopal. That path continues to shape how I approach robotics: model the system carefully, make assumptions explicit, and test ideas on real platforms.
More about me